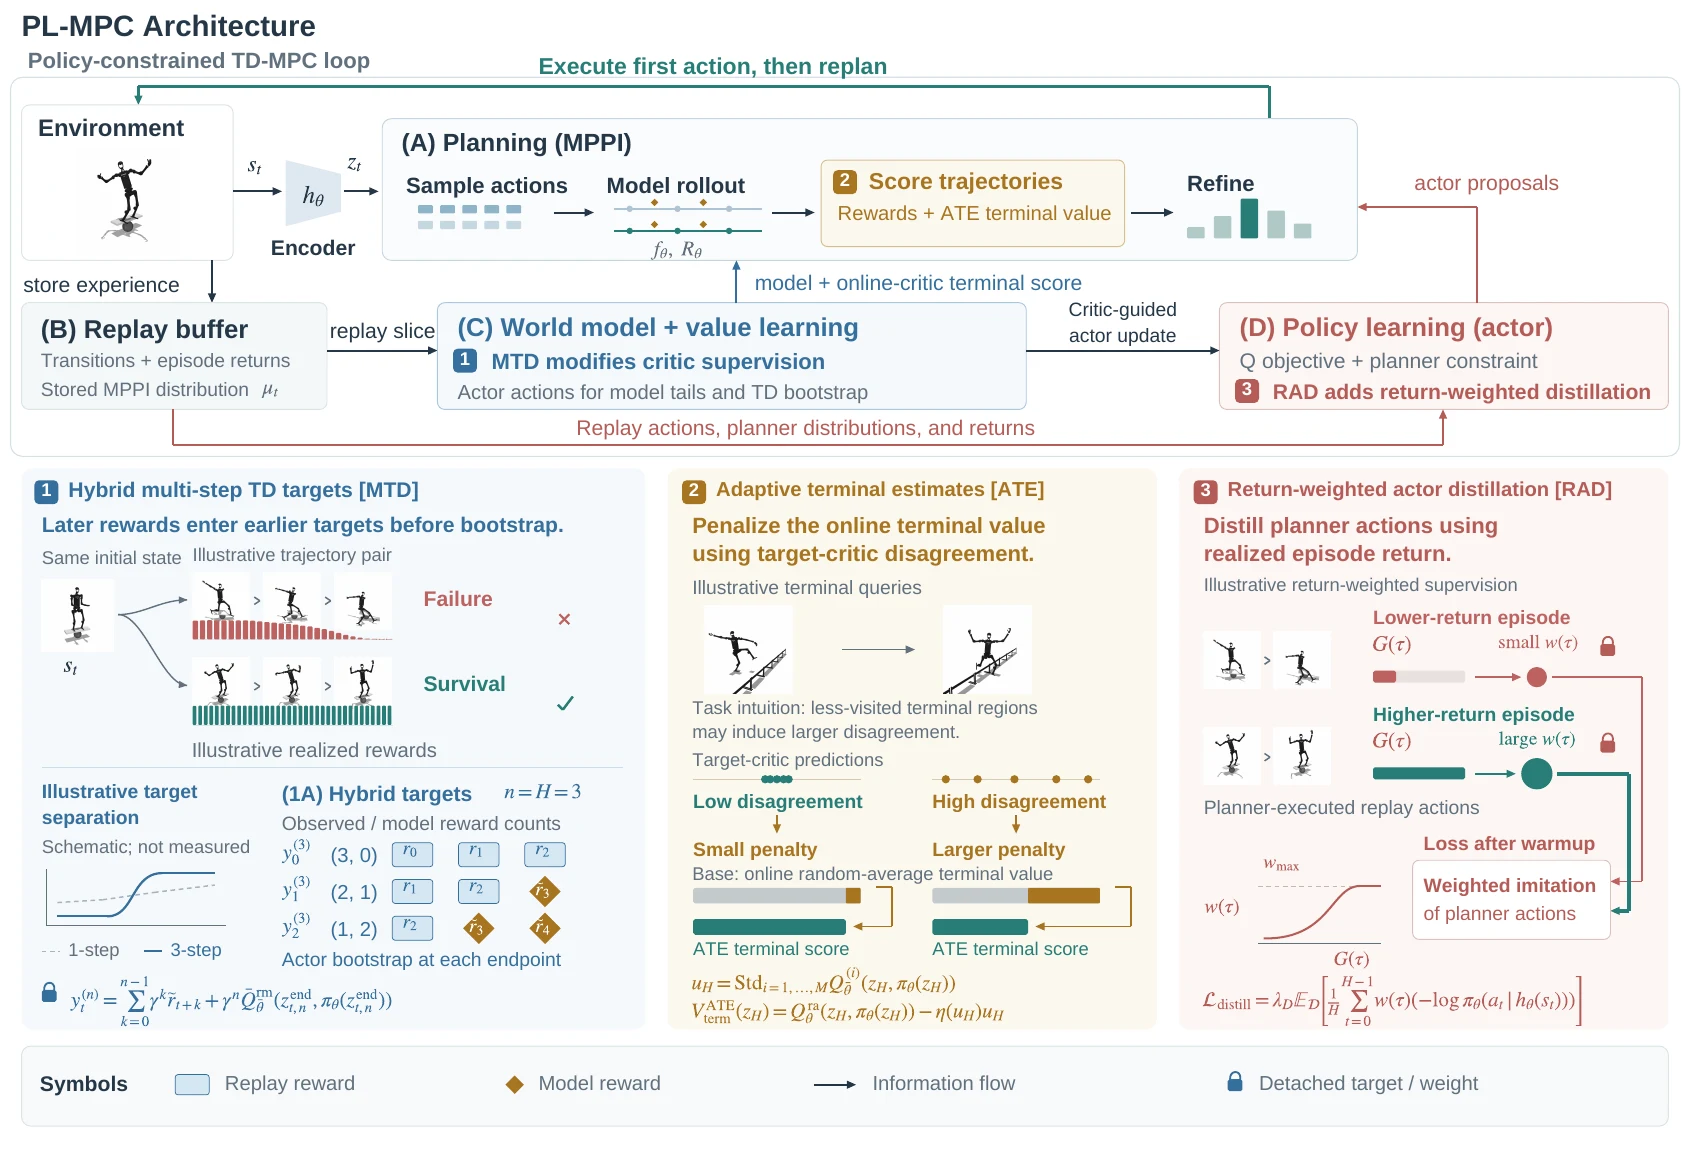
PL-MPC: Beyond Policy Alignment: Closing the Planning–Learning Loop for Robot Control with Learned World Models
Under review
Closing the loop between planning and learning for humanoid control and zero-shot sim-to-real manipulation.

I’m a third-year Ph.D. student in Computer Science at Rutgers University, advised by Prof. Abdeslam Boularias.
I have nearly 4 years of research experience in robot learning and planning, spanning 3D scene understanding, object rearrangement, dynamic manipulation, and model-based reinforcement learning for humanoid locomotion. I have published at CoRL and IROS.
My current research explores action abstractions from human motion capture for planning with learned world models toward robust humanoid loco-manipulation. I also study Q-guided planning for vision-language-action (VLA) policies.
Under review
Closing the loop between planning and learning for humanoid control and zero-shot sim-to-real manipulation.
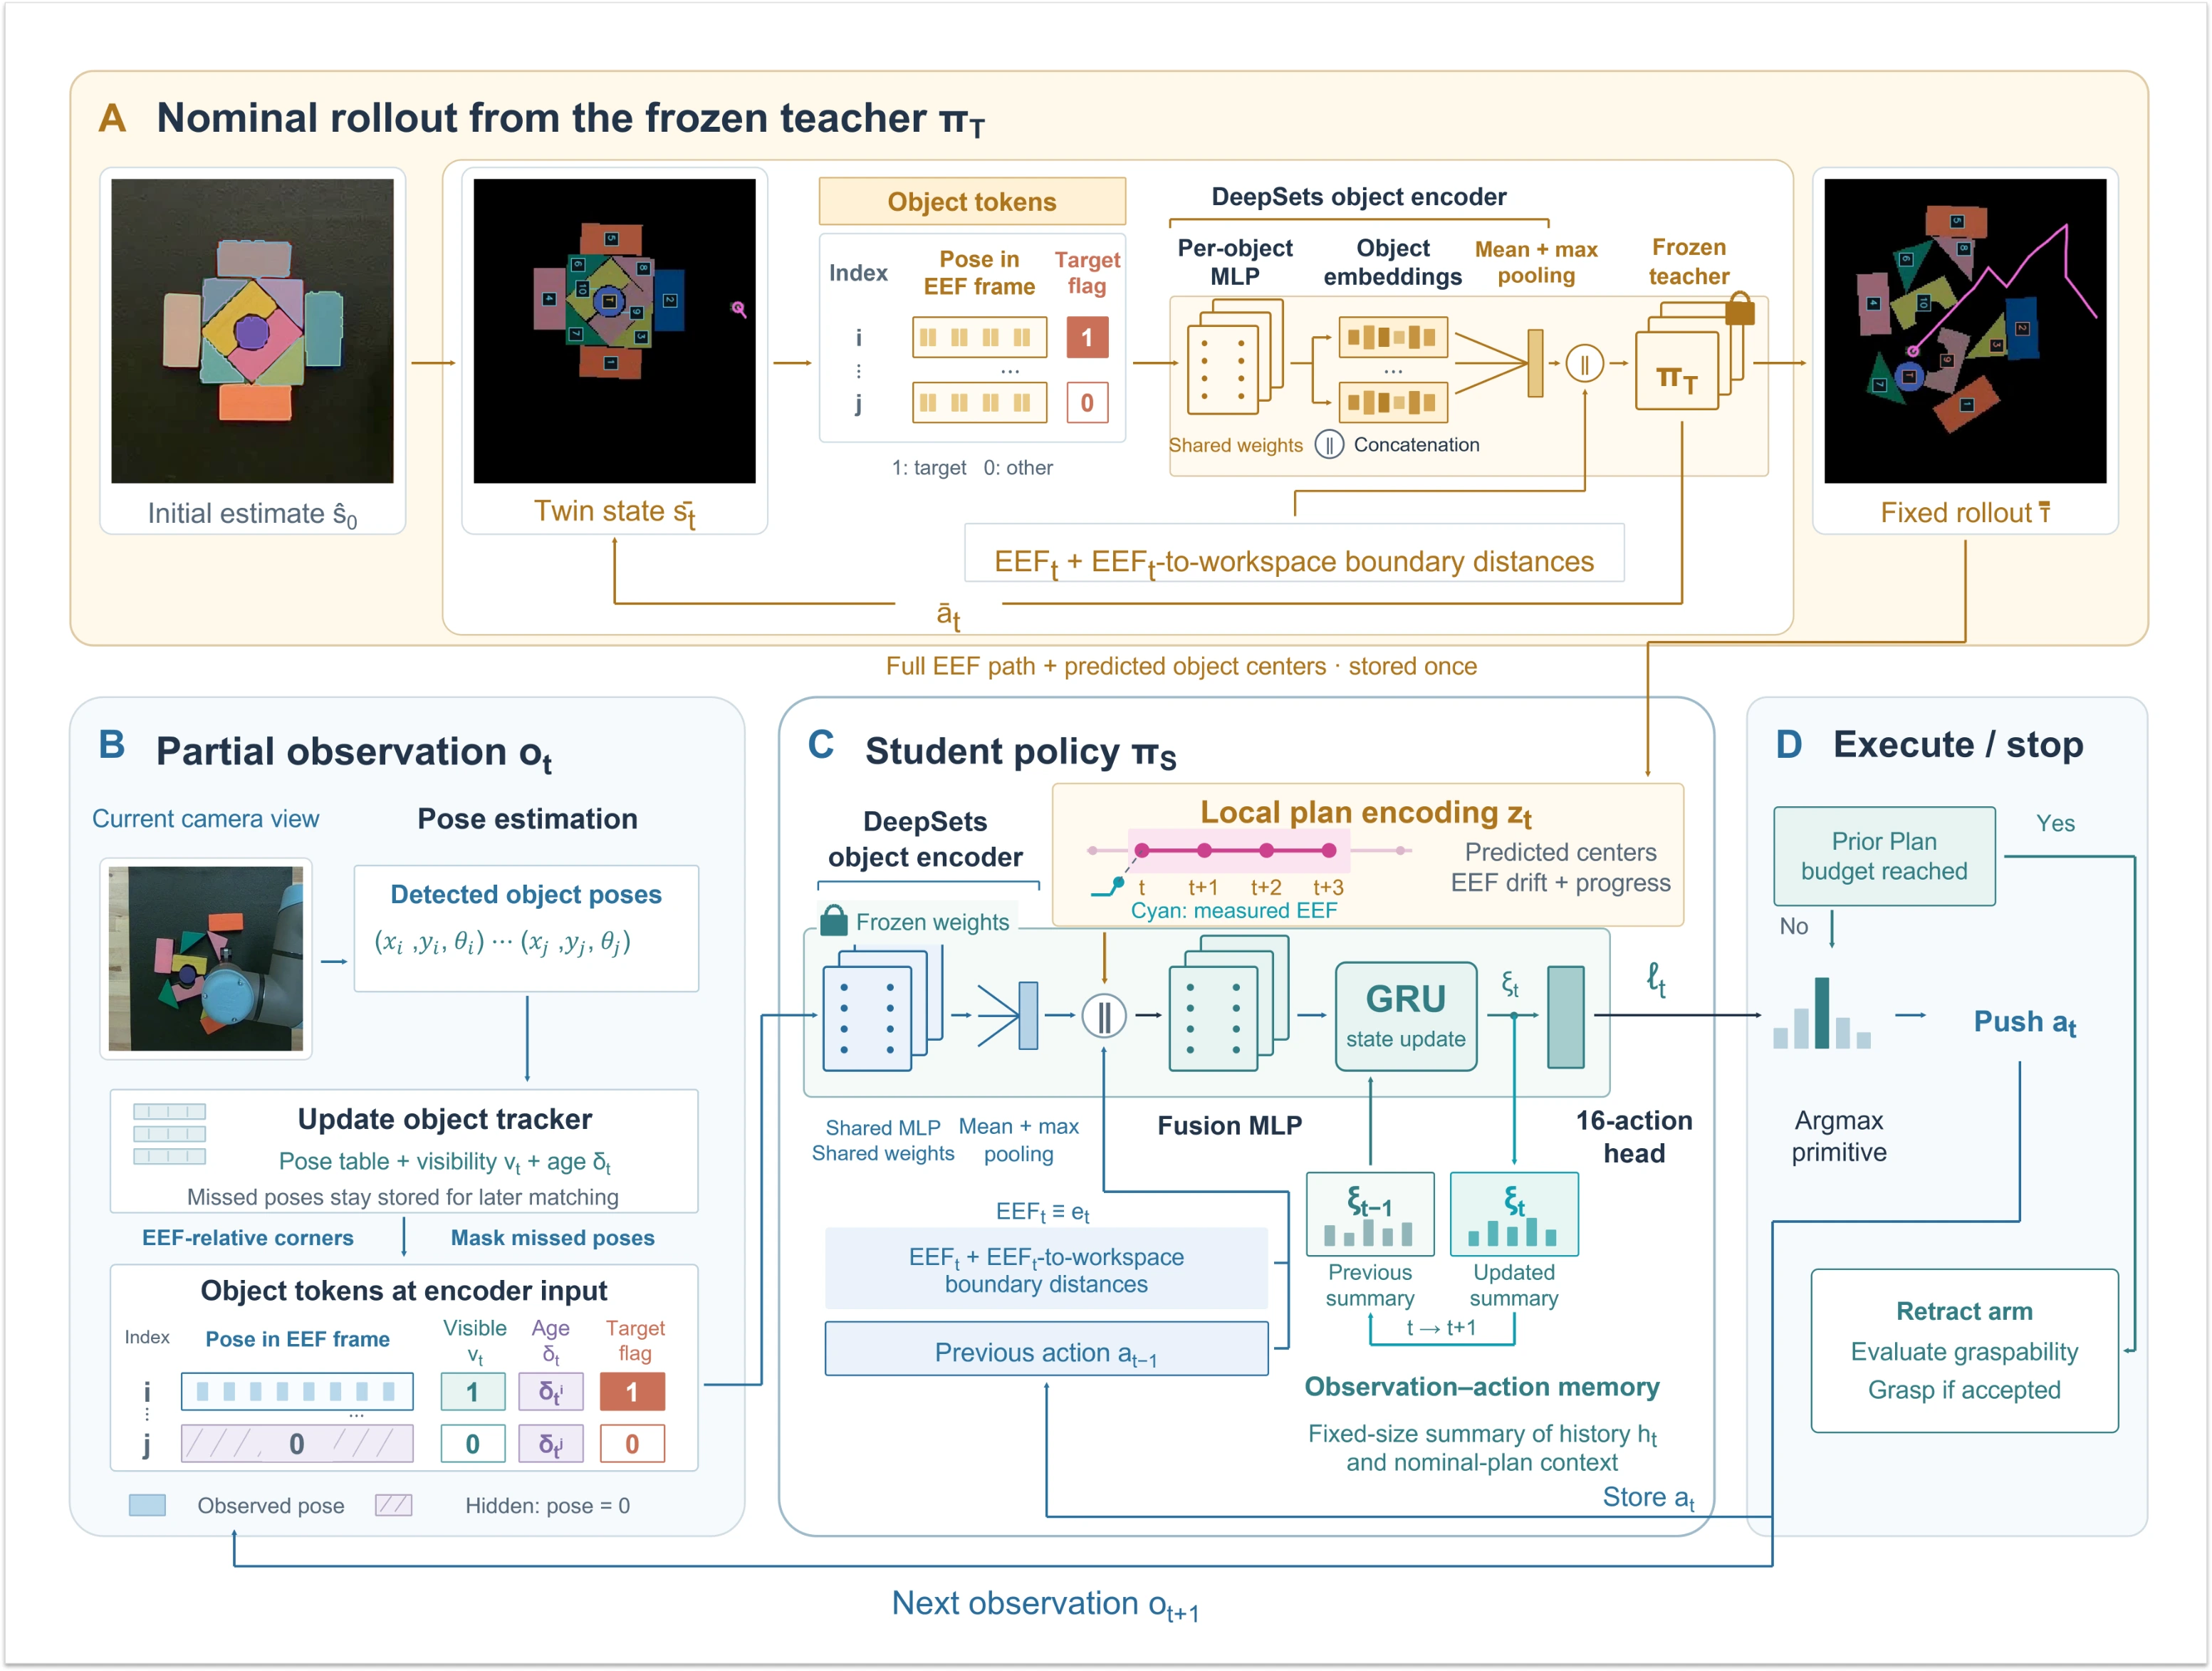
Under review
Retrieving objects from dense clutter despite camera occlusion, using plan-conditioned imitation learning.

IROS, 2025
Tracking and grasping moving objects with reinforcement learning and Kalman filtering, including recovery from tracking loss and failed grasps.

IROS, 2024
Diffusion-based affordance prediction for placing objects in containers with different storage modes.

IROS, 2024
Turning language instructions into executable object rearrangements through geometric reasoning and tree search.

CoRL, 2023
Grounding free-form language queries in open-vocabulary 3D scene graphs.
ESEC/FSE, 2022
A tool to specify energy-aware self-adaptive location-sensing strategies helping developers write battery-aware code for mobile apps.
ICSME, 2022
A command-line tool to assist developers in evaluating projects by providing quantitative scores for ten metrics that span project collaboration, quality and maintenance.
ICPC, 2022
A Chrome plugin to augment GitHub with badges that deliver visual cues quantifying the project's architecture and maintenance.
CVIP, 2021
We report here a platform and a model building algorithm that does auto-annotation of documents by building models in real-time.
Fall 2026
CS440: Introduction to Artificial Intelligence, Course Instructor, Rutgers University
Spring 2026
CS440: Introduction to Artificial Intelligence, Teaching Assistant, Rutgers University
Fall 2025
CS460: Introduction to Computational Robotics, Teaching Assistant, Rutgers University
Spring 2025
CS440: Introduction to Artificial Intelligence, Teaching Assistant, Rutgers University
Fall 2024
CS440: Introduction to Artificial Intelligence, Teaching Assistant, Rutgers University
2024 – present
Rutgers University
Sep 2022 – Oct 2024
Rutgers University
2017 – 2021
Indian Institute of Technology Tirupati
Previously, I worked with Prof. Sridhar Chimalakonda and Prof. Kalidas Yeturu at IIT Tirupati, and visited the University of Waterloo.